
Introduction — a quick question to start
Have you ever stood at a transit depot and watched an electric bus hover for seconds that feel like minutes, wondering if those pauses were planned or avoidable?
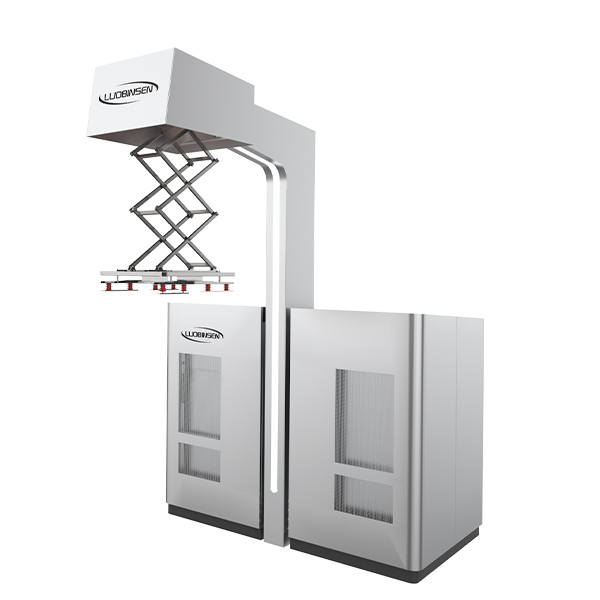
I often map those moments back to the timing of a pantograph charger — the exact instant a connector meets a bus can determine whether a fleet stays on schedule or slides into delays. Recent data shows that dwell-time inefficiencies can shave up to 12% off daily operational capacity for some fleets (simple math, big impact). So what small choices in scheduling, alignment, and device calibration lead to such outsized problems? Let’s unpack that — and then look at better options.
Traditional solution flaws and hidden user pain points
What’s really failing at the depot?
When I examine pantograph for electric bus deployments, the first thing I notice is that many legacy systems assume ideal conditions. They rely on fixed schedules and manual alignment checks. In real life, buses arrive early, late, or slightly off position. Contact wear increases. Power converters handle surges poorly. Communication protocols between the vehicle and charger are often basic, so errors cascade instead of being isolated. These are not exotic problems — they’re daily grind issues that spike maintenance costs and reduce uptime.
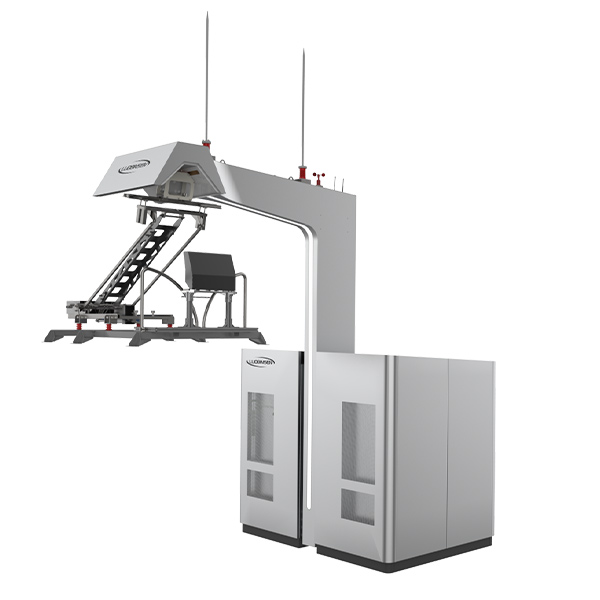
Look, it’s simpler than you think: small misalignments cause repeated mechanical stress (contact wear), and without smart monitoring the team only notices when a failure happens. The pain points are human and technical. Drivers waste time nudging vehicles into place. Technicians chase symptoms instead of root causes. And management sees higher total cost of ownership. Edge computing nodes could help by processing alignment sensors locally, but many installations still push raw data to a central server and wait — and wait (delay equals lost revenue). I’ve seen fleets where scheduling rigidity alone cut charging throughput by nearly a third — funny how that works, right?
Future outlook: new principles and how to evaluate next-gen systems
What’s next for smarter charging?
Looking ahead, I favor solutions built on a few clear principles: real-time alignment verification, adaptive power control, and open communication standards. At the depot level an electric ev charging station that integrates position sensors with the charger’s control logic can reduce missed connections dramatically. Predictive maintenance, driven by local analytics, flags a worn contact before it fails — which keeps buses moving and reduces emergency technician dispatches.
We should measure any new system against three practical metrics: (1) effective charging uptime — the percentage of scheduled charge events completed without human intervention; (2) mean time between failures for mechanical contact systems; and (3) energy transfer efficiency under real-world alignment variance. These metrics tell you whether a vendor’s pitch translates into operational gain. I recommend small pilots that run during peak and off-peak windows to validate assumptions; that way you avoid wide-scale surprises. Also — and this matters — ask how the system handles edge cases like rapid fleet growth or temporary lane closures. Those scenarios expose architectural weaknesses fast.
In short, move beyond headline specs and focus on alignment resilience, communication protocols, and smart power conversion. We’ve learned that modest investments in sensing and local control pay dividends in uptime and cost reduction. For teams evaluating vendors, keep the metrics above front and center, test in live conditions, and insist on clear upgrade paths. If you want a place to start, consider the practical products and support offered by Luobisnen. I’ve seen incremental changes there translate into major operational wins — measurable, not hypothetical.