
Introduction
Have you ever watched a small setup in a lab and wondered whether it tells the whole story?
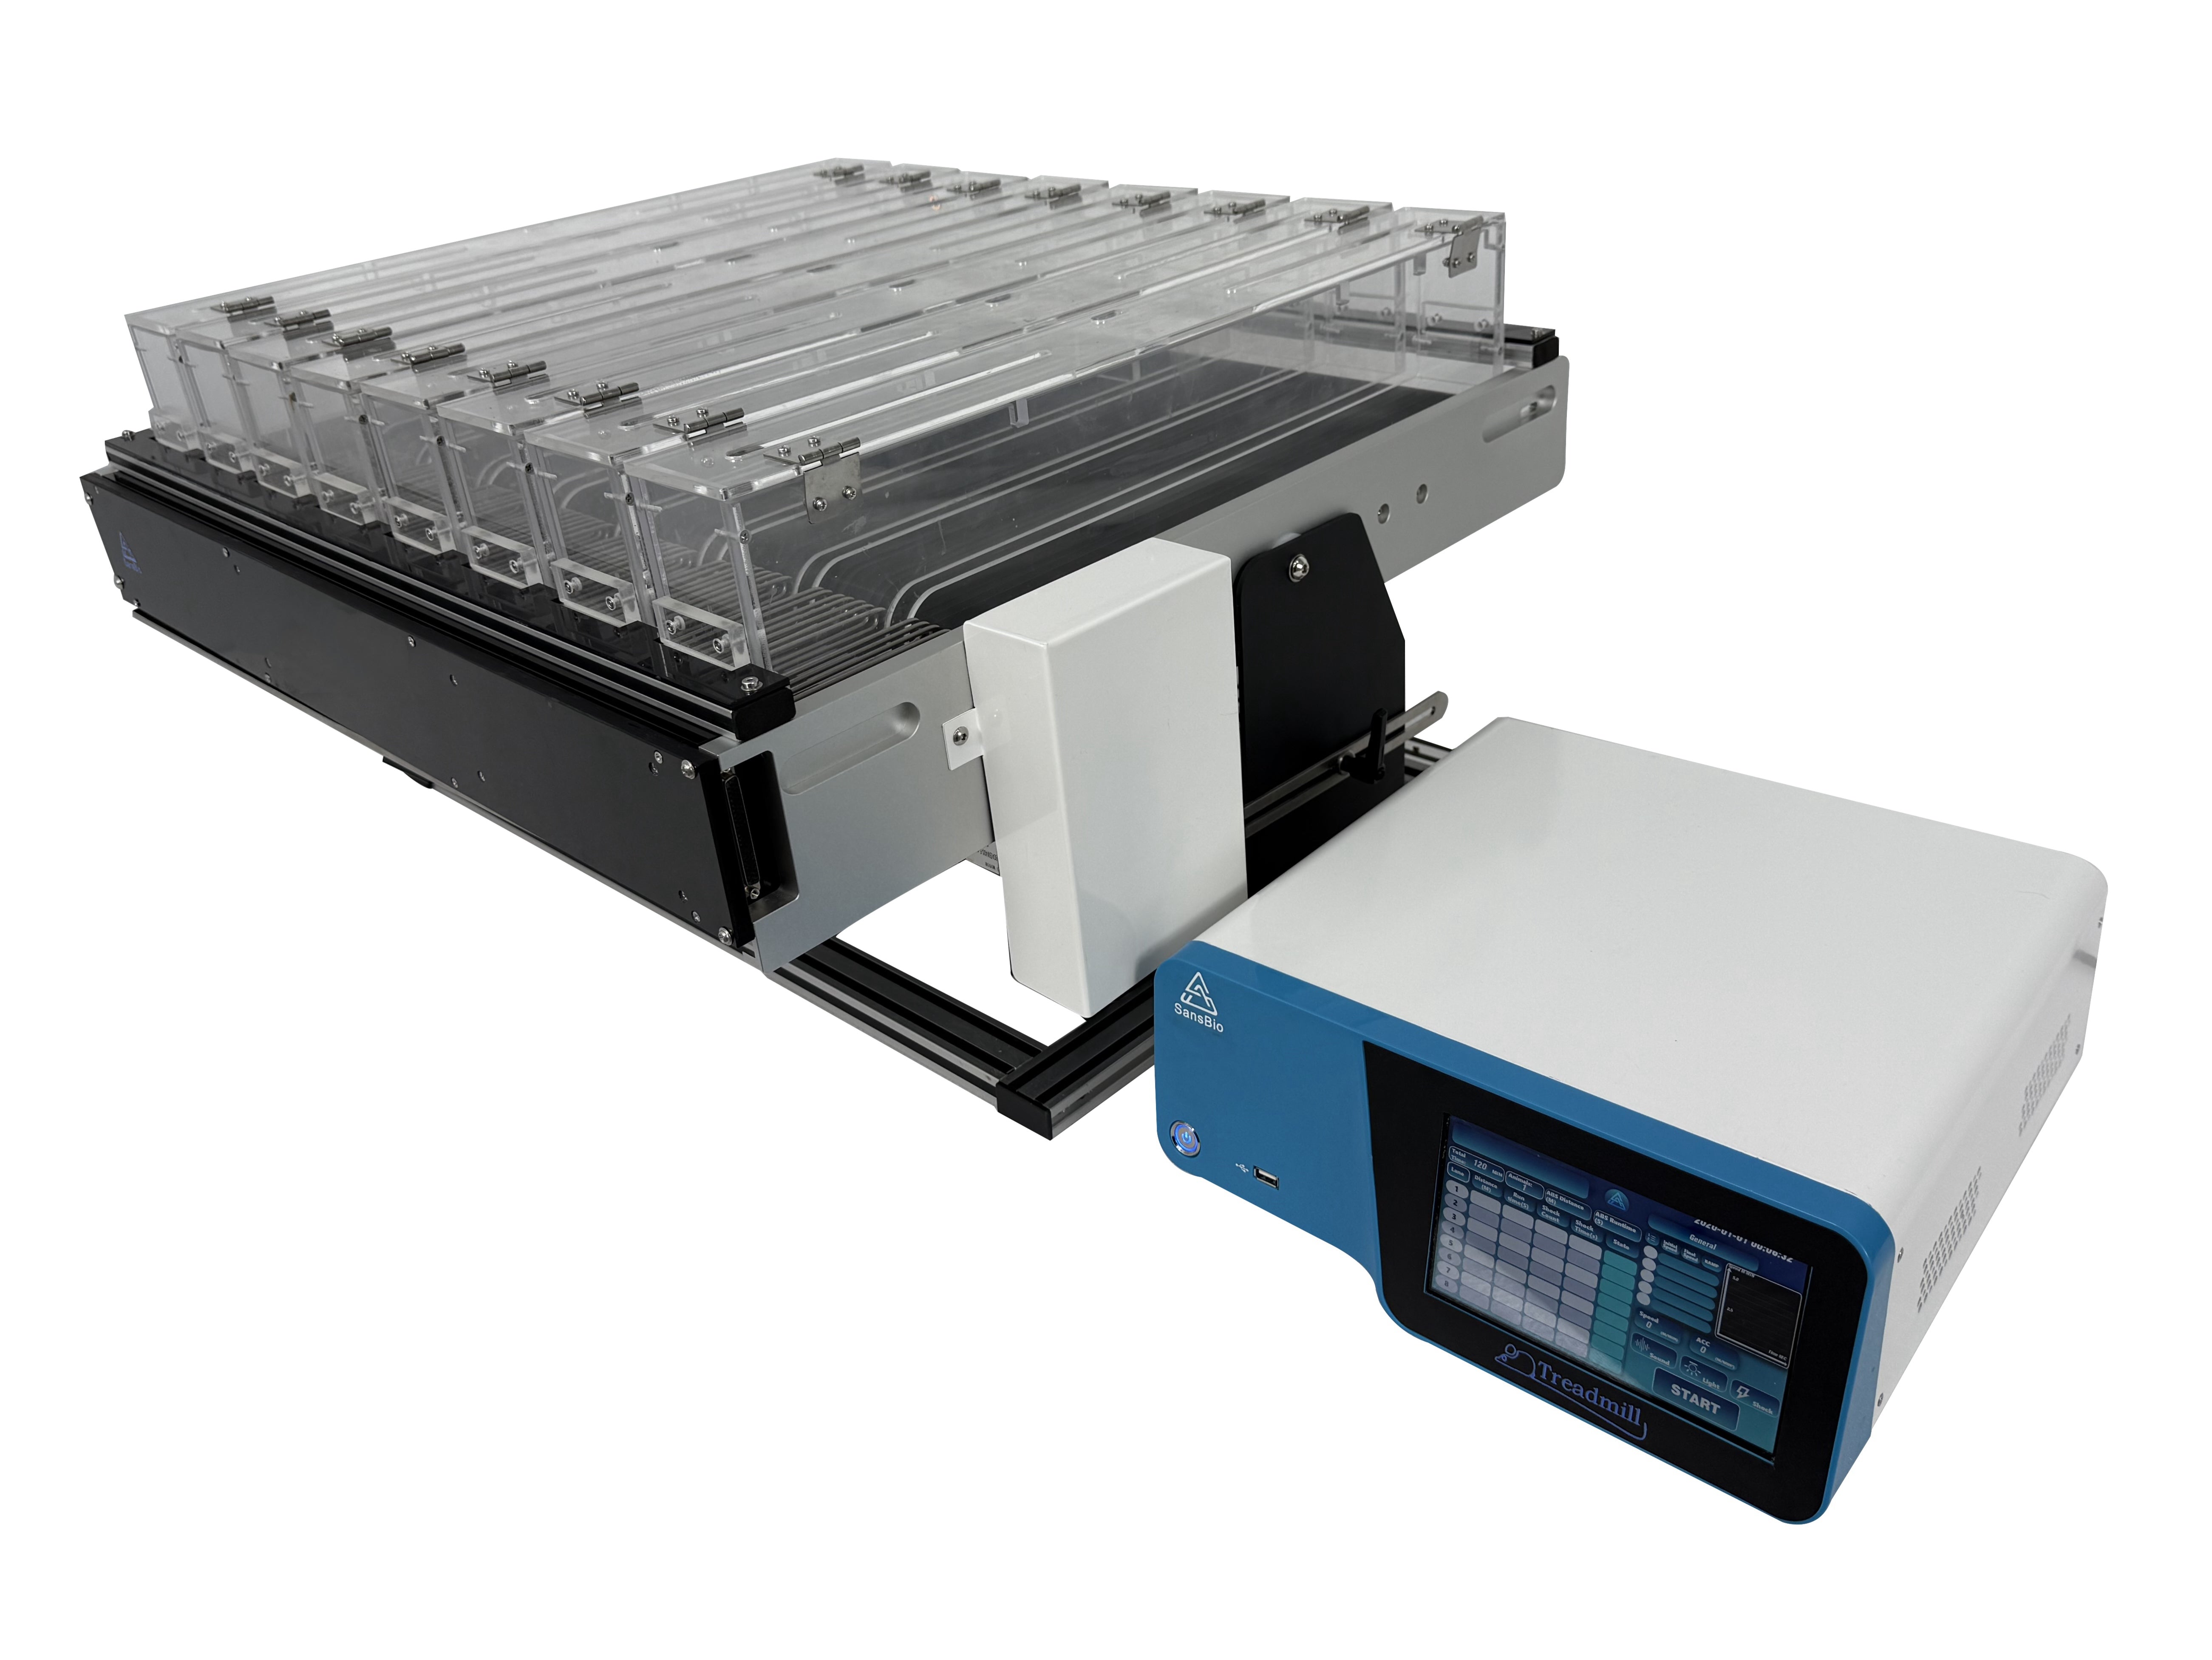
I remember standing by a row of running wheels while a mouse treadmill hummed quietly nearby, and the numbers on the monitor didn’t match what we felt was happening in the room — many labs report inconsistent throughput and repeatability (roughly a third of small studies show variable results). What explains that gap between instrument readouts and real behaviour? It’s a fair question, and one I’ll keep returning to as we look deeper into hardware, firmware and data flow.
The scene is simple: a rodent on a belt, a controller, a screen. But the details — calibration, force sensors, data acquisition timing — change the story. So, how do we compare systems in a way that actually helps researchers choose the right setup? Let’s move on and unpack the weak links that typically hide in plain sight.
Hidden Flaws in Traditional Rodent Treadmill Setups
What’s breaking under the hood?
I link to rodent treadmill because I want us to be concrete: many platforms look robust until you probe timing jitter, belt slip, or control-loop lag. In my experience, those are the three quiet culprits. Let me be blunt — when a servo motor lags or a force sensor drifts, the behavioural metric you trust becomes noise. We call out drift, hysteresis and aliasing in lab notes, but I’ve seen teams underestimate how much a single loose encoder or an aging power converter warps longitudinal data.
Technically speaking, the control path matters. Too often a treadmill’s PID loop is tuned on bench tests, not on living animals, so closed-loop stability fails under variable loading. Add poor data acquisition sampling and you get mismatch between stimulus and response. Look, it’s simpler than you think: synchronize the belt controller with your recording system, validate the force sensors, and log timestamps from edge computing nodes. — funny how that works, right?
Future Outlook: Better Designs and Practical Choices
What’s Next for Labs and Designers?
We can choose two routes now: patch old designs or adopt systems built around precise timing and modular telemetry. I’m leaning toward modularity. Modern systems blend local compute (small edge computing nodes) with reliable actuators and high-resolution encoders. When I test a new rodent treadmill, I check how easily it integrates with my lab’s data acquisition stack and whether it exposes raw sensor streams. If it doesn’t, I’m skeptical.
Case example: a lab I worked with swapped an older belt for a unit with better encoder feedback and reworked the sampling strategy. Within weeks they reduced behavioural variance and improved statistical power — not magic, just careful attention to synchronization and sensor fidelity. There are trade-offs: cost versus control, simplicity versus flexibility. We evaluate those trade-offs in practical terms, and I often ask: can I reproduce this across cohorts? — short answer: sometimes, but only after tightening the whole measurement chain.
To finish, here are three evaluation metrics I now insist on when choosing or upgrading a treadmill system: 1) Temporal fidelity — sub-millisecond timestamping across sensors and actuators; 2) Closed-loop stability — proven PID tuning under load and during perturbations; 3) Data transparency — access to raw sensor streams and clear metadata (calibration records, sampling rates). Use these to compare vendors and setups; they matter more than glossy GUIs or bundled scripts. For practical procurement and integration, I often point colleagues to established suppliers who document these metrics well — for example, check BPLabLine as a place to start when you need recorded specs and support.